Dmodel Multi-Objective Optimization Example
This page introduces the Dmodel_moo project.
Compared with the Dmodel project, Dmodel_moo is configured for multi-objective optimization.
optimization.yaml (Dmodel_moo project)
The contents of optimization.yaml, which configures the optimization, are shown below.
For this multi-objective shape optimization, the decomposition_ensemble multi-objective optimization algorithm is selected. See the corresponding documentation page for details.
evaluator:
  name: pyemsol_shape_evaluator
optimizer:
  name: decomposition_ensemble
  kwargs:
    num_decomposition: 5
    seed: 42
optimization_problem.yaml (Dmodel_moo project)
The contents of optimization_problem.yaml are the same as in the Dmodel project. However, because the optimization algorithm handles a multi-objective problem, each entry in objectives is treated as an independent objective function.
objectives:
  - function_name: average_torque
    kwargs:
      torque_scale: 4.0
    normalization_const: 2.1
    coefficient: -1.0
  - function_name: torque_ripple_percentage
    kwargs:
      torque_scale: 4.0
    normalization_const: 54.0
    coefficient: 1.0
Thus, the multi-objective optimization problem defined here is as follows.
: Average torque [Nm]
: Torque ripple percentage [%]
Optimization Example
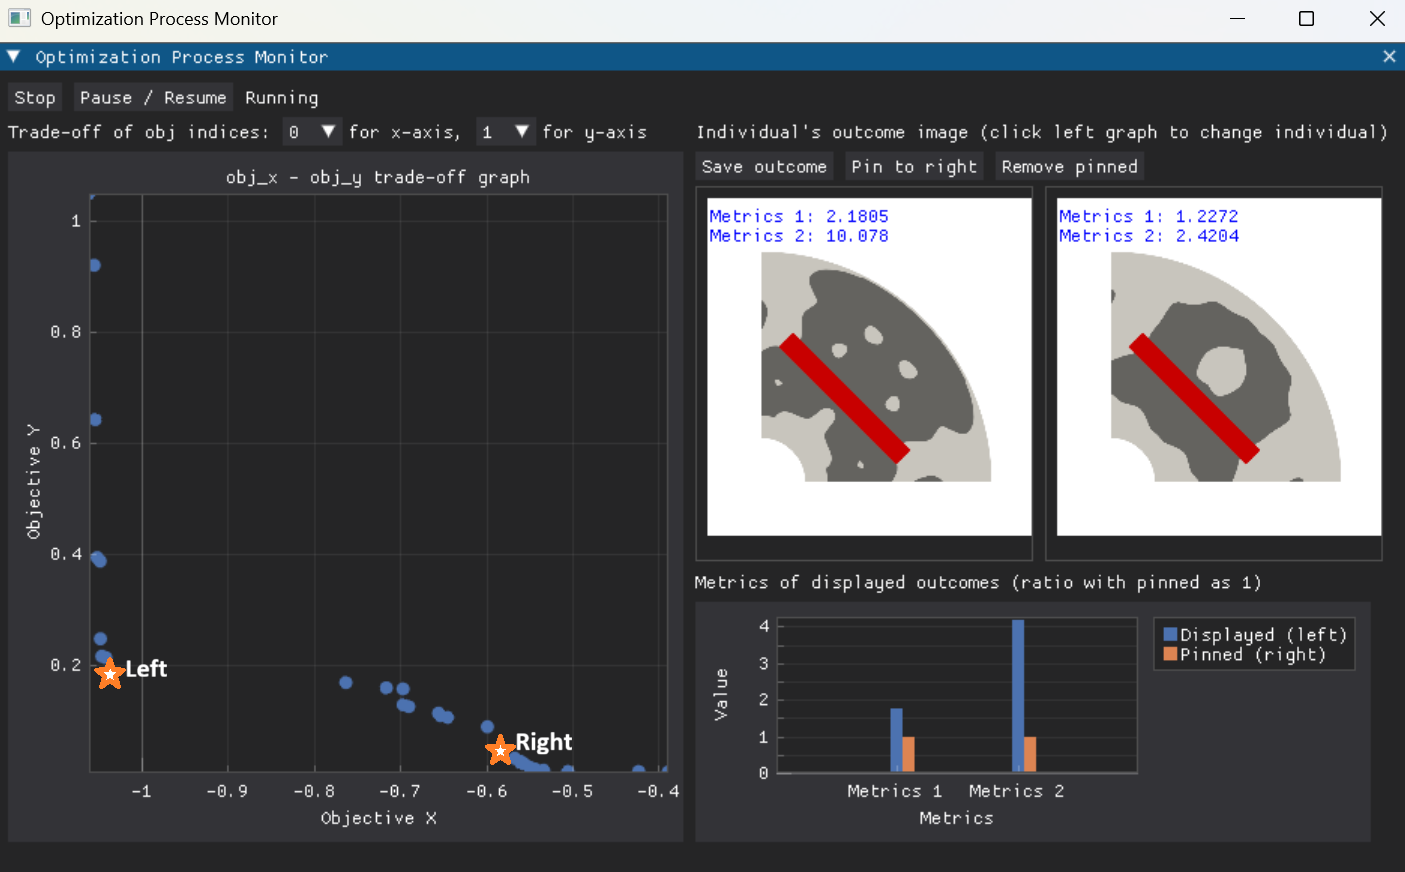
Optimization was performed with Implicit Domain Meshing enabled (use_implicit_domain_meshing: True). The GUI after 100 optimization iterations is shown below.
Because the number of decompositions was set to 5, the Pareto front is sparse, but the solutions cover a broad range. The average torque reaches a plateau around (), suggesting that this is the limit of the average torque under these settings.
The displayed shapes are the solutions labeled "Left" and "Right" in the Pareto-front plot. "Left" achieves both high average torque and low torque ripple and is close to the result of Basic Optimization. "Right", on the other hand, focuses on reducing torque ripple; its value is very low at 2.42%, but the magnetic core has moved away from the rotor surface, resulting in a much lower average torque. A constraint requiring the average torque to remain above a certain value could prevent this (see the IPM8P48S example).